Event submissions
Published
This submission belongs to the session S4. Process Control, Monitoring and Machine Learning of the event The 5th International Electronic Conference on Processes
Published date
15 Oct, 2026
Academic Editor
 Ravendra Singh
Citation
Naima Rahoua, Nassima BEKHOUCHA, Abir Betka, Abida Toumi, Optimal PID Parameter Tuning for BLDC Motor Using MRFO Algorithm, in Proceedings of The 5th International Electronic Conference on Processes, 20 October–22 October 2026, MDPI: Basel, Switzerland
Share
Email
Facebook
Twitter
LinkedIn
Optimal PID Parameter Tuning for BLDC Motor Using MRFO Algorithm

Naima Rahoua 1
Nassima BEKHOUCHA 1

Abir Betka 2
Abida Toumi 1
1. Department of Electrical Engineering, University of Biskra, Biskra, Algeria
2. Department of Electrical Engineering, University of El-oued, El Oued, Algeria
Abstract
This paper investigates the application of the Manta Ray Foraging Optimization (MRFO) algorithm for optimal tuning of PID controller parameters in brushless DC (BLDC) motors, with the Integral of Time-weighted Absolute Error (ITAE) serving as the fitness function. The MRFO algorithm, inspired by the foraging strategies of manta rays, is employed to efficiently search the parameter space and identify optimal PID gains that minimize ITAE, thereby enhancing the dynamic performance of BLDC motor control systems. Our study compares the proposed MRFO-based PID controller with a conventional PID controller and demonstrates significant improvements in speed control stability, overshoot reduction, faster rise times, lower steady-state errors, quicker settling times, and overall performance of the BLDC control system. Additional simulation scenarios under high-speed operation and speed reversal conditions further demonstrate the effectiveness of the proposed controller under different operating conditions. These results demonstrate the effectiveness of the MRFO algorithm for PID controller optimization compared with the conventional PID controller in this control scheme. The MRFO algorithm’s ability to avoid local minima and its ease of integration into control system design make it a promising tool for real-time controller optimization. Overall, the study demonstrates the effectiveness of the proposed MRFO-based PID controller in achieving high-performance BLDC motor control, providing a practical and effective solution for advanced motor drive applications. The proposed method also offers computational efficiency, implementation simplicity, scalability, and adaptability, supporting its application in future intelligent industrial automation and advanced electric drive systems.
Keywords
BLDC motor
PID controller
ITAE
Manta Ray Foraging Optimization (MRFO)
Speed control
Poster
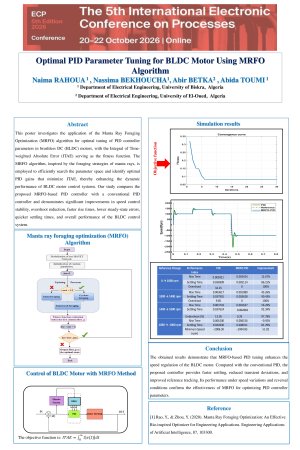
poster MDPI Pr Rahoua 2026.pdf
Hybrid Deep Learning Optimization of Catalytic Parameters in Anaerobic Digestion for Enhanced Biogas Production
Novel Sensing polymeric Nano-composite materials for CO2 Gas Detection