Event submissions
Published
This submission belongs to the session S3. Guidance, Navigation, and Control of the event Drones 2026: Mapping the Knowledge
Published date
12 Nov, 2026
Citation
Nicholas Edmond, Simon Esau, Reza Ahmari, Genetic Algorithm for Terrain-Optimized Routing for UAV and eVTOL Corridor Navigation, in Proceedings of Drones 2026: Mapping the Knowledge, Barcelona, 11 November–13 November 2026, MDPI: Basel, Switzerland
Share
Email
Facebook
Twitter
LinkedIn
Genetic Algorithm for Terrain-Optimized Routing for UAV and eVTOL Corridor Navigation

Nicholas Edmond 1
Simon Esau 1
Reza Ahmari 1
1. North Carolina A&T State University
Abstract
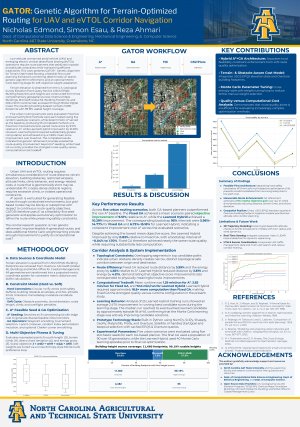
Urban low-altitude operations for unmanned aerial vehicles (UAVs) and emerging electric vertical takeoff and landing (eVTOL) corridor concepts require planners that both guarantee feasibility under hard constraints and optimize metrics linked to energy and safety margins. This work introduces the "GATOR" pipeline, which stands for Genetic Algorithm for Terrain-Optimized Routing. GATOR uses a feasible-first hybrid architecture to solve this routing problem. First, a deterministic 2D grid A* planner finds initial paths that satisfy hard-constraint feasibility like geo-fences and obstacle envelopes. Second, a genetic algorithm (GA) refines these paths over a constrained search space seeded by the feasible A* paths to improve distance, clearance, and climb metrics. Third, a lightweight Monte Carlo tuning loop, designed like a cross-entropy search, stabilizes soft-cost preferences across episodes. To test the pipeline, terrain elevation data is pulled from the USGS Elevation Point Query Service (EPQS), and building footprints are gathered from OpenStreetMap. In experimental run artifacts, the GA refinement successfully improved the best seed objective by approximately 5.5% while strictly preserving path feasibility and maintaining a stable minimum altitude above ground level (AGL) profile. This hybrid approach demonstrates highly repeatable corridor discovery under strong constraints.
Keywords
UAV path planning
eVTOL
corridor navigation
A* search
genetic algorithm
terrain-aware routing
Poster
GATOR poster.pdf
A First Step towards Noise-Aware Mission Planning through Acoustic Geofencing
From Threat Intelligence to Safe Paths: Cooperative UAV–UGV Navigation in Contested Urban Search and Rescue